Inverse Kinematics for a 2-Link Robot Arm in Python: From Target Point to Servo Commands
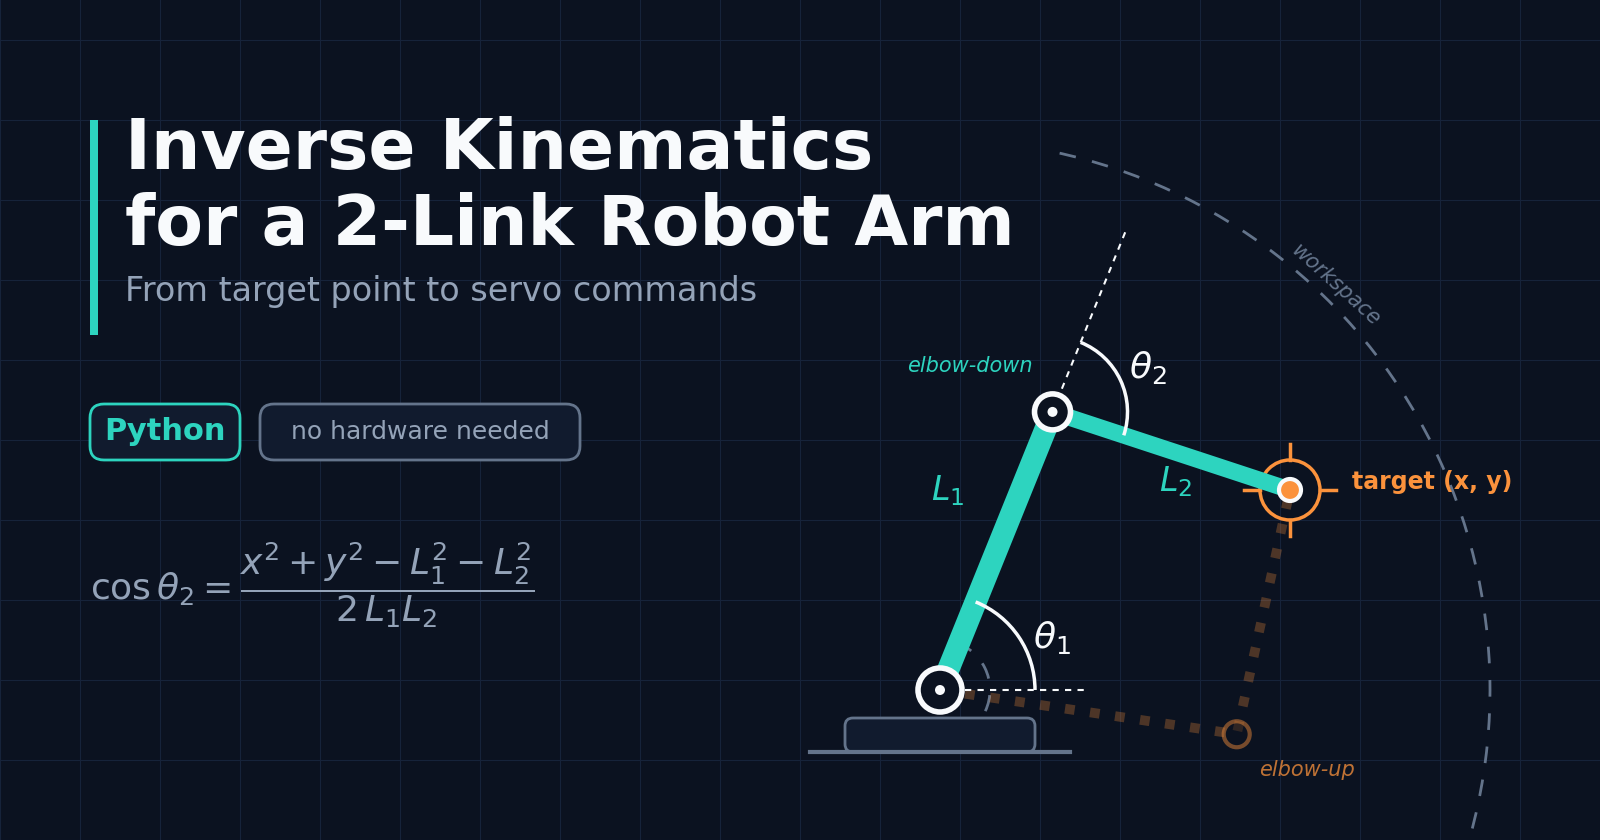
A robot arm is told where to put its gripper, but its motors only understand joint angles. Inverse kinematics (IK) is the step that converts one into the other. It sounds advanced, yet a two-link plan
Responses
Markdown supported · ⌘↵ to post
No responses yet.