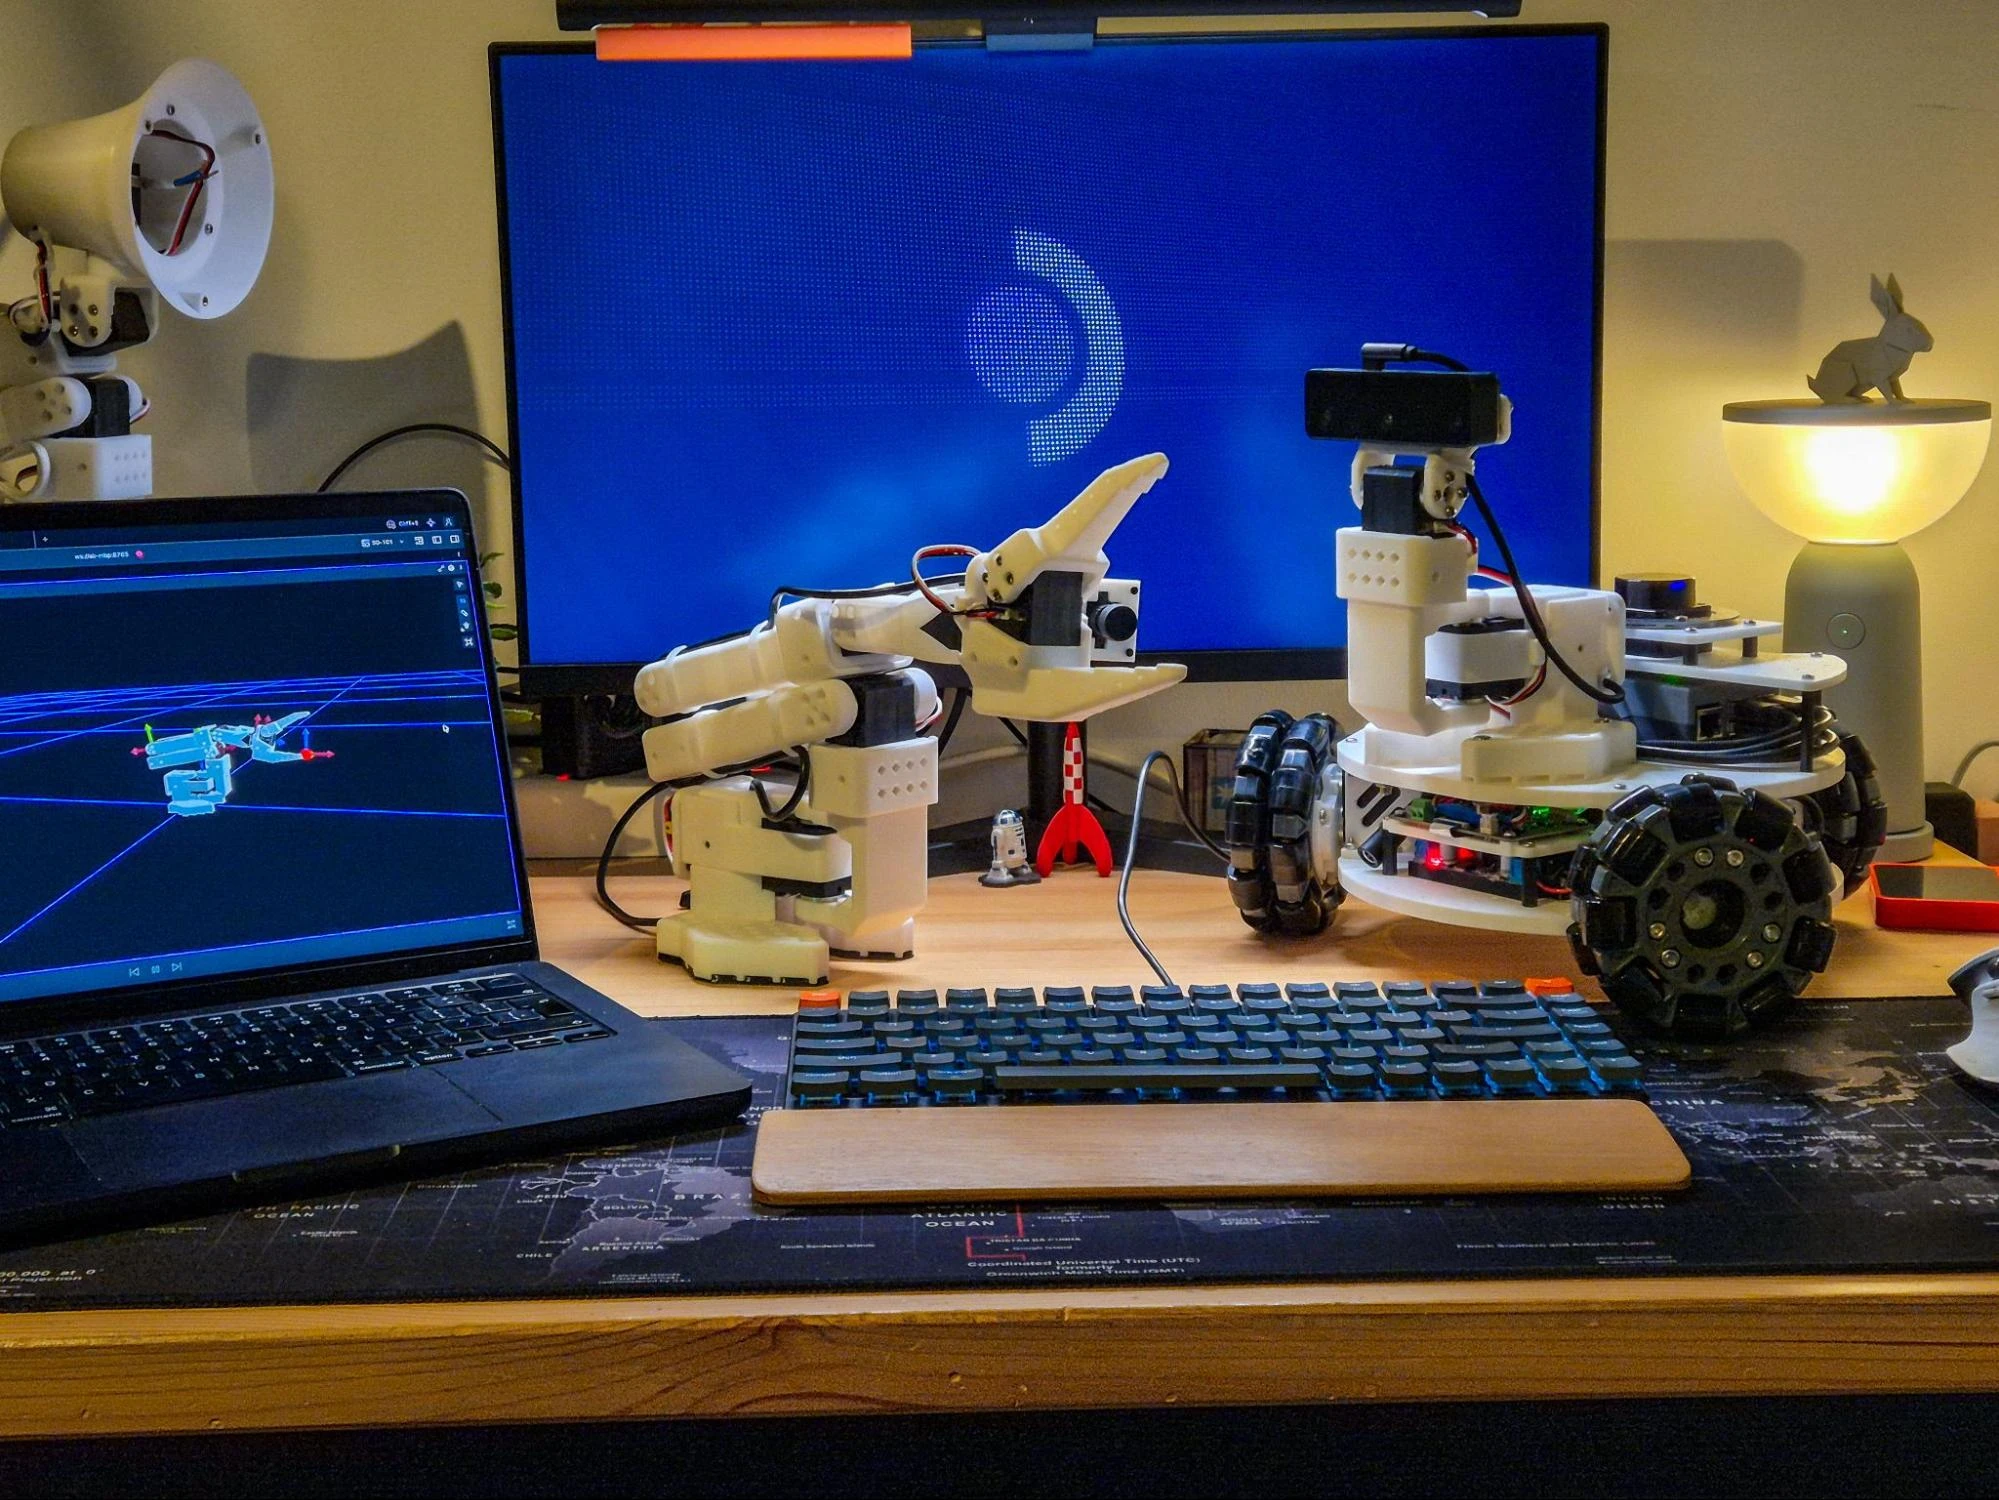
Using Foxglove as an SO-101 Simulator
tl;dr: While on a little hiatus from the LeKiwi robot, I decided to build a new SO-101 arm and, in parallel, decided to work on the software side first - using ROS 2 Control and sts_hardware_interface
kamathrobotics.com9 min read